HFS-MF6
Multi-axis Force Sensor
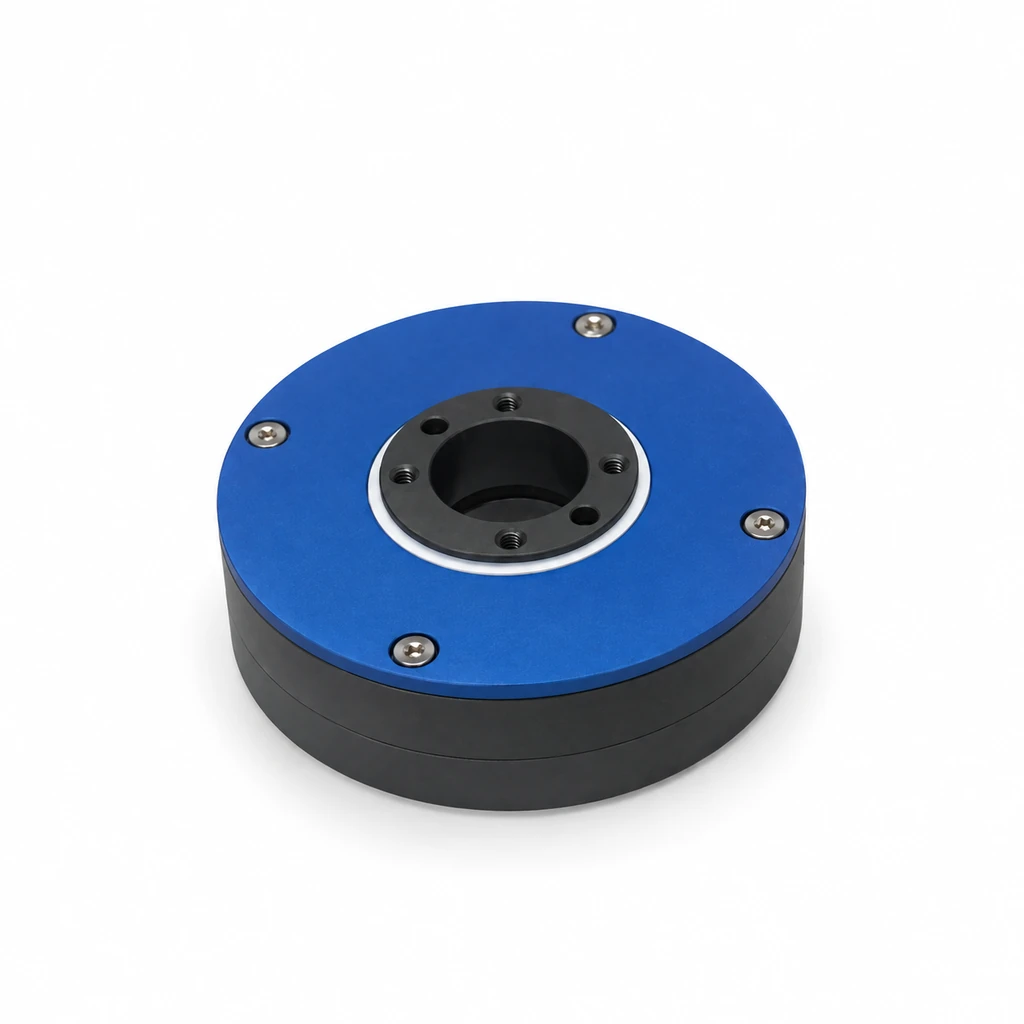
HFS-MF6 resistive multi-axis force sensor with an integrated connector, for robot force and torque measurement.
- Selected Z-axis range
- 5–25 kg
- Accuracy
- ±0.1 N
- Selected output type
- Analogue voltage
Supplied by WKSENSOR. Ask us about pricing, availability and delivery.
Product overview
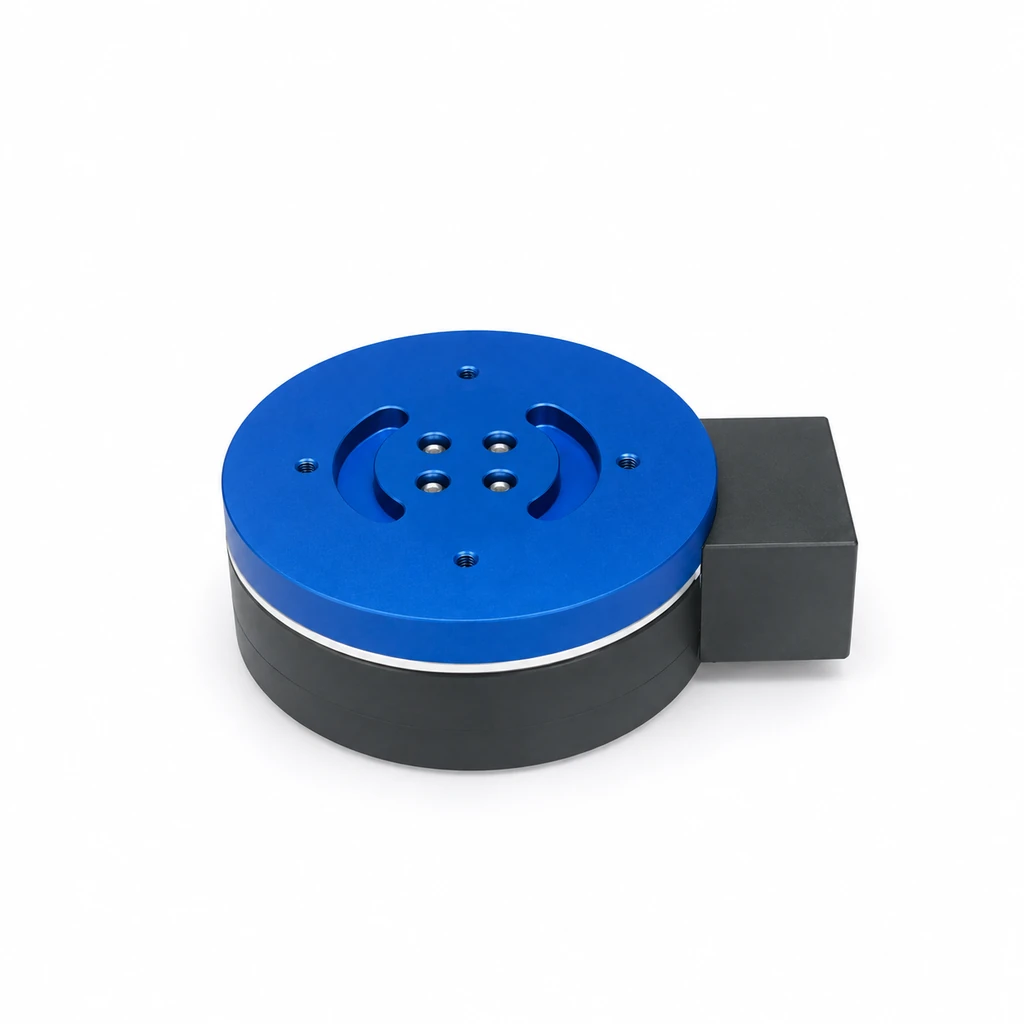
Circular sensing body
Resistive multi-axis force and torque sensing for robot wrist and hand measurements.
Bridge-cable reference
The 14-pin bridge-reference cable uses the assignments below. Its bridge creep is ±0.05% FS.
| Signal | Positive (+) | Negative (−) |
|---|---|---|
| Excitation | Pin 1 · red | Pin 2 · black |
| Fx | Pin 3 · yellow | Pin 4 · black |
| Fy | Pin 5 · blue | Pin 6 · black |
| Fz | Pin 7 · white | Pin 8 · black |
| Mx | Pin 9 · yellow | Pin 10 · brown |
| My | Pin 11 · blue | Pin 12 · brown |
| Mz | Pin 13 · white | Pin 14 · brown |
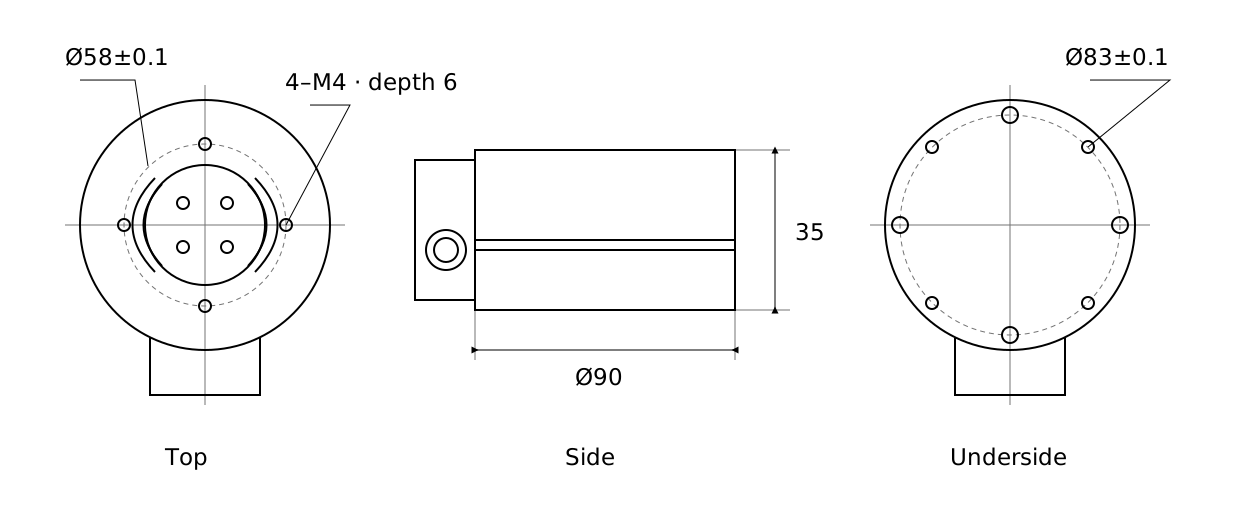
Mounting circles and connector profile
The top and underside use different mounting patterns. The top four M4 holes have a drawing depth of 6; the drawing also marks nominal 45° angular relationships. Dimensional units require confirmation. Confirm the mounting circles, thread depths and connector clearance for your selected sensor before designing the fixture.
- Body diameter / height
- Ø90 / 35
- Top mounting circle
- Ø58±0.1
- Underside mounting circle
- Ø83±0.1
- Top threads
- 4–M4, depth 6
Configuration and selection
- Selected configuration
- For the 5–25 kg Z-axis selection, analogue-voltage output and ±0.1 N accuracy are specified. Confirm the required axis ratings, output and bridge characteristics together for the ordered version.
- Force and torque references
- Force-capacity alternatives of 50, 100, 200 or 250 N; torque-capacity alternatives of 2, 4, 8 or 10 N·m.
- Bridge-reference sensitivity and linearity
- Sensitivity is given as 1.5–2.0 ±0.05 mV/V. Published nonlinearity values are ±0.05–±0.1% FS, with ≤±0.05% FS linearity also specified for the selected version. Confirm the applicable sensitivity, linearity limit and test conditions for your axis configuration.
- Capacity-table output references
- Force-capacity output sensitivity: 0.5–1.0 mV/V. Torque-capacity output sensitivity: 1.0–1.5 mV/V.
- Connection
- Integrated-connector construction; a 3 m cable with a 14-pin connector is specified for the illustrated configuration.
- Material
- Aluminium-alloy or stainless-steel options. The illustrated capacity table describes an aluminium-alloy configuration.
Technical reference
Specifications and options
| Parameter | Specification or option |
|---|---|
| Model | HFS-MF6 |
| Sensor type | Resistive multi-axis force sensor |
| Selected Z-axis range | 5–25 kg |
| Accuracy | ±0.1 N |
| Selected output type | Analogue voltage |
| Bridge-reference hysteresis error | ±0.05% FS |
| Bridge-reference repeatability error | ±0.05% FS |
| Zero temperature coefficient | ±0.05% FS / 10 °C |
| Sensitivity temperature coefficient | ±0.05% FS / 10 °C |
| Bridge input resistance | 380 ±30 Ω / 750 ±30 Ω |
| Bridge output resistance | 350 ±5 Ω / 700 ±5 Ω |
| Operating temperature | −20–70 °C |
| Safe overload | 150% FS |
| Insulation resistance | ≥2000 MΩ |
| Bridge excitation | 5–12 V |
| Protection | IP65 |
| Material options | Aluminium alloy / stainless steel |
| Reference cable and connector | 3 m cable; 14-pin connector |
| Brand | WKSENSOR |
| Product reference | HH-759025712653 |
Application scenarios
Multi-axis force and torque measurement in robotics, including robot wrist and hand-force measurements. Other specified uses include aerospace and medical equipment.
- Robotics
- Robot wrist and hand forces and moments.
- Aerospace
- Multi-axis measurement applications.
- Medical equipment
- Force-measurement applications.
Further application areas include injection moulding, automotive equipment, water conservancy, batching and lifting.